Samuel Marriage

About Me

I came to engineering through software, first teaching myself Python as a school student. I was fascinated by the speed at which code could be made to work, leading me to build small projects; a 2D platformer, text based games, a few utilities.

However, over time software felt incomplete on its own and I felt my creative and imaginative sides were left underexplored. Thus, the prospect of combining logical thinking with creativity to work on systems that operate in the physical world drew me to robotics.

Since discovering my passion for robotics, I have worked on a variety of projects; from an autonomous maze-solving robot, to a bionic 'tensegrity' quadruped. These projects have given me great hands-on exposure to a variety of robotics concepts, and I'm always looking forward to where robotics will take me next.

Quick Highlights

  • Developed the software to bridge the gap from simulation to real-world application on a bionic 'tensegrity' quadruped
  • Designed and built a fully autonomous maze-solving robot with closed-loop control and multi-sensor fusion
  • Developed 2 real-time physics simulations with stable multi-body collision handling
  • Member of Queen Mary's ECHO lab (view here)
  • Member of Queen Mary Electronics Society
  • Ex-Member of the York Engineering Society
  • Represented Computer Science at Sixth Form open evenings, encouraging students to pursue STEM at GCSE

My Work

Relevant projects I have worked on over the years. Outlining the task, what I implemented, and the results.

TQbot: Bio-inspired Quadruped

Robotics ROS2 Python Raspberry Pi

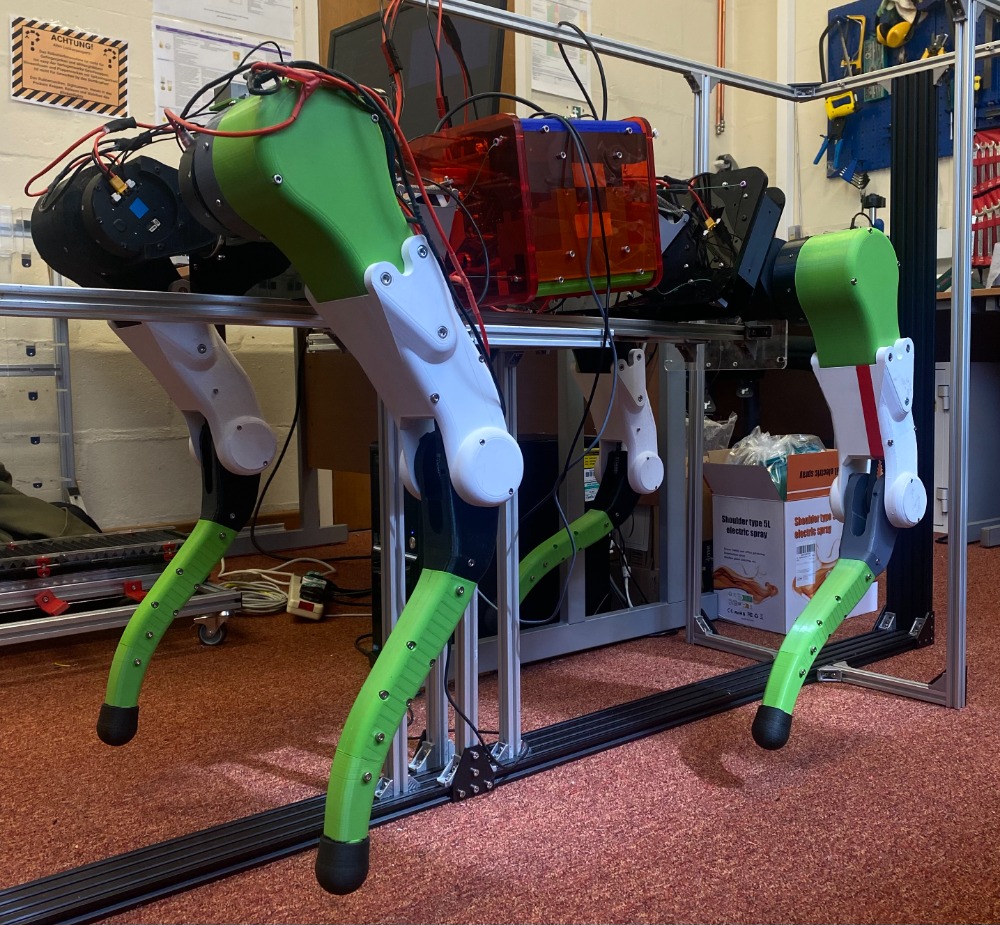
Dissertation project developing the motor control software for TQbot, a quadruped robot with a bio-inspired tensegrity spine providing all three spinal degrees of freedom, and fifteen system-wide degrees of freedom.

Implements a three-layer ROS2 multi-motor control architecture that commands sixteen Unitree A1 motors across six RS485 buses. The system is commanded from a Python control shell, and safeguarded through a safety layer.
Dissertation Repo

Skills: ROS2 | Python | Hybrid PD Control | Inverse Kinematics | RS485 Communication | Multithreading | Safety Systems | Unit Testing
Autonomous Maze Solving Robot

Robotics Embedded C++ Arduino

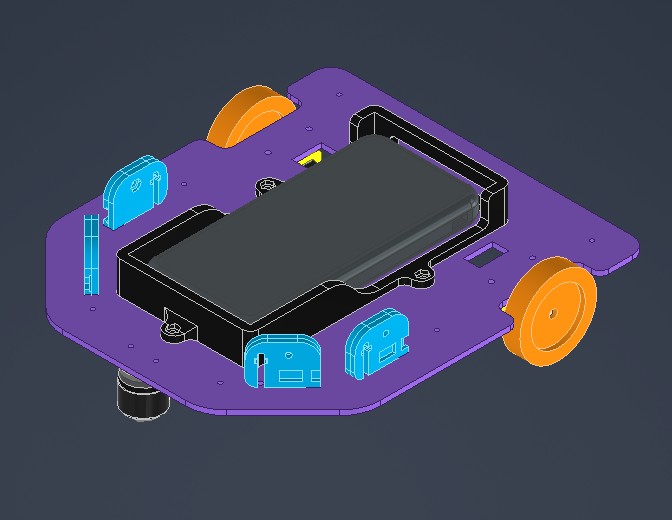
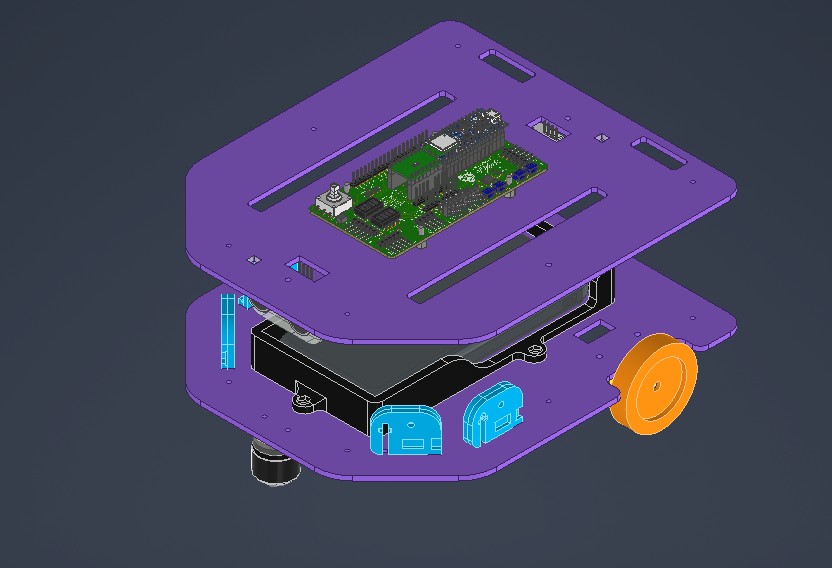
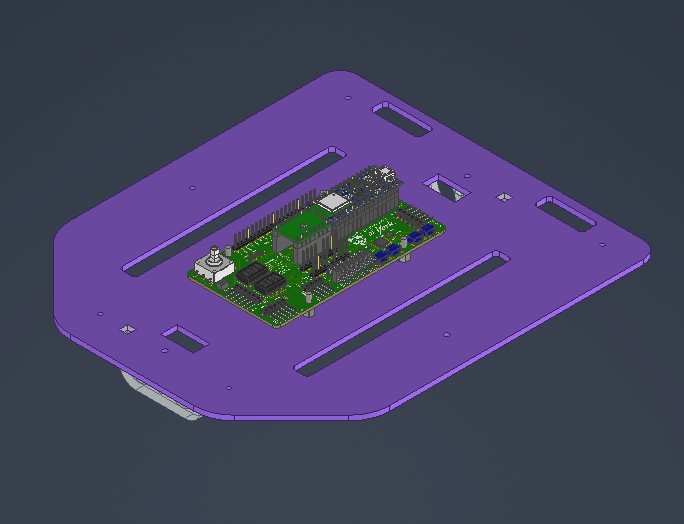
A fully autonomous differential-drive robot with a custom-built chassis, using the Arduino Nano 33 BLE to navigate unknown maze environments.

Houses 4 infrared sensors, 2 ultrasonic sensors, 2 motors, and a custom-built battery pack holder.

Design Breakdown

Skills: Embedded C++ | Robotics | FSMs | Sensor Fusion | Wheel Odometry | Gyroscope Integration | Bluetooth Communication

FollowerFeuds

Simulation Python

A BeyBlade-style game implementing a real-time 2D physics simulation built in Python, attracting 400+ daily users on TikTok.

Implements rigid-body motion, collision detection, and momentum transfer. Using a modular state-driven architecture, capable of handling continuous real-time updates.

Repo Tiktok

Skills: Physics Simulation | Real-Time Systems | Collision Detection | State Machines | Game Architecture

Flocking Simulator

Simulation Java

Real-time flocking simulation in Java, applying object-oriented programming principles to simulate emergent flocking behaviour in autonomous boids.

Each boid follows rules for cohesion, alignment, and separation, whilst maintaining avoidance of static obstacles on a 2D canvas.

Try it! Write-Up

Skills: Java | Object-Oriented Design | GUI Development | Real-Time Systems | Collision Detection | Simulation

Parameterisable Processor

Simulation VHDL

A parameterisable processor datapath in VHDL, built to be reusable, and simulated within Vivado 2023.2.

Modular components including an ALU, register bank, and control logic are used to execute a custom single-cycle multiplication routine.

Write-Up

Skills: VHDL | Digital Logic Design | FSMs | Parameterisation | Vivado | Simulation | Hardware Verification

Want more?

Public Repos can be found on my GitHub, further information / private repos may be available upon request.

Skills

Programming Languages

  • C++
  • Python
  • Java
  • VHDL
  • MATLAB
  • SQL
  • HTML5
  • CSS
  • JavaScript

Libraries/Frameworks

  • ROS2
  • Pygame
  • Java AWT
  • Arduino BLE
  • mbed

Software/Tools

  • Visual Studio
  • Arduino IDE
  • STM32CubeIDE
  • PyScripter
  • Eclipse
  • Vivado
  • LTSpice
  • Autodesk Inventor
  • Fusion360

Experience

Postgraduate Student

Sept 2026 - Sept 2027

Queen Mary University of London - London, UK

  • Member of the ECHO lab (view here)
  • Member of Queen Mary Electronics Society

Undergraduate Student

Sept 2023 - July 2026

University of York - York, UK

  • Member of York Engineering Society
  • Relevant Coursework: Quadruped Robot Dissertation Project | Robotics Design & Construction | Advanced Sensors & Instrumentation | Control, Sensors, & Instrumentation

Engineering Intern

July 2022

Ocado - Hatfield, UK

  • Completed an engineering experience placement, working with various software, simulation, and deployment teams, gaining insight into engineering workflows, code review processes, and system integration in a large scale environment.

Computer Science Assistant

Sept 2022 - July 2023

Goffs Academy - Cheshunt, UK

  • Assisted teaching 20+ GCSE Students, increasing understanding of Python and Computing Theory, leading to improved exam scores.

Contact

Get in Touch

The fastest way to reach me is via email: [email protected]

CV

Download my CV below.